
News · missionSTACK research
The swarm now has a reflex.
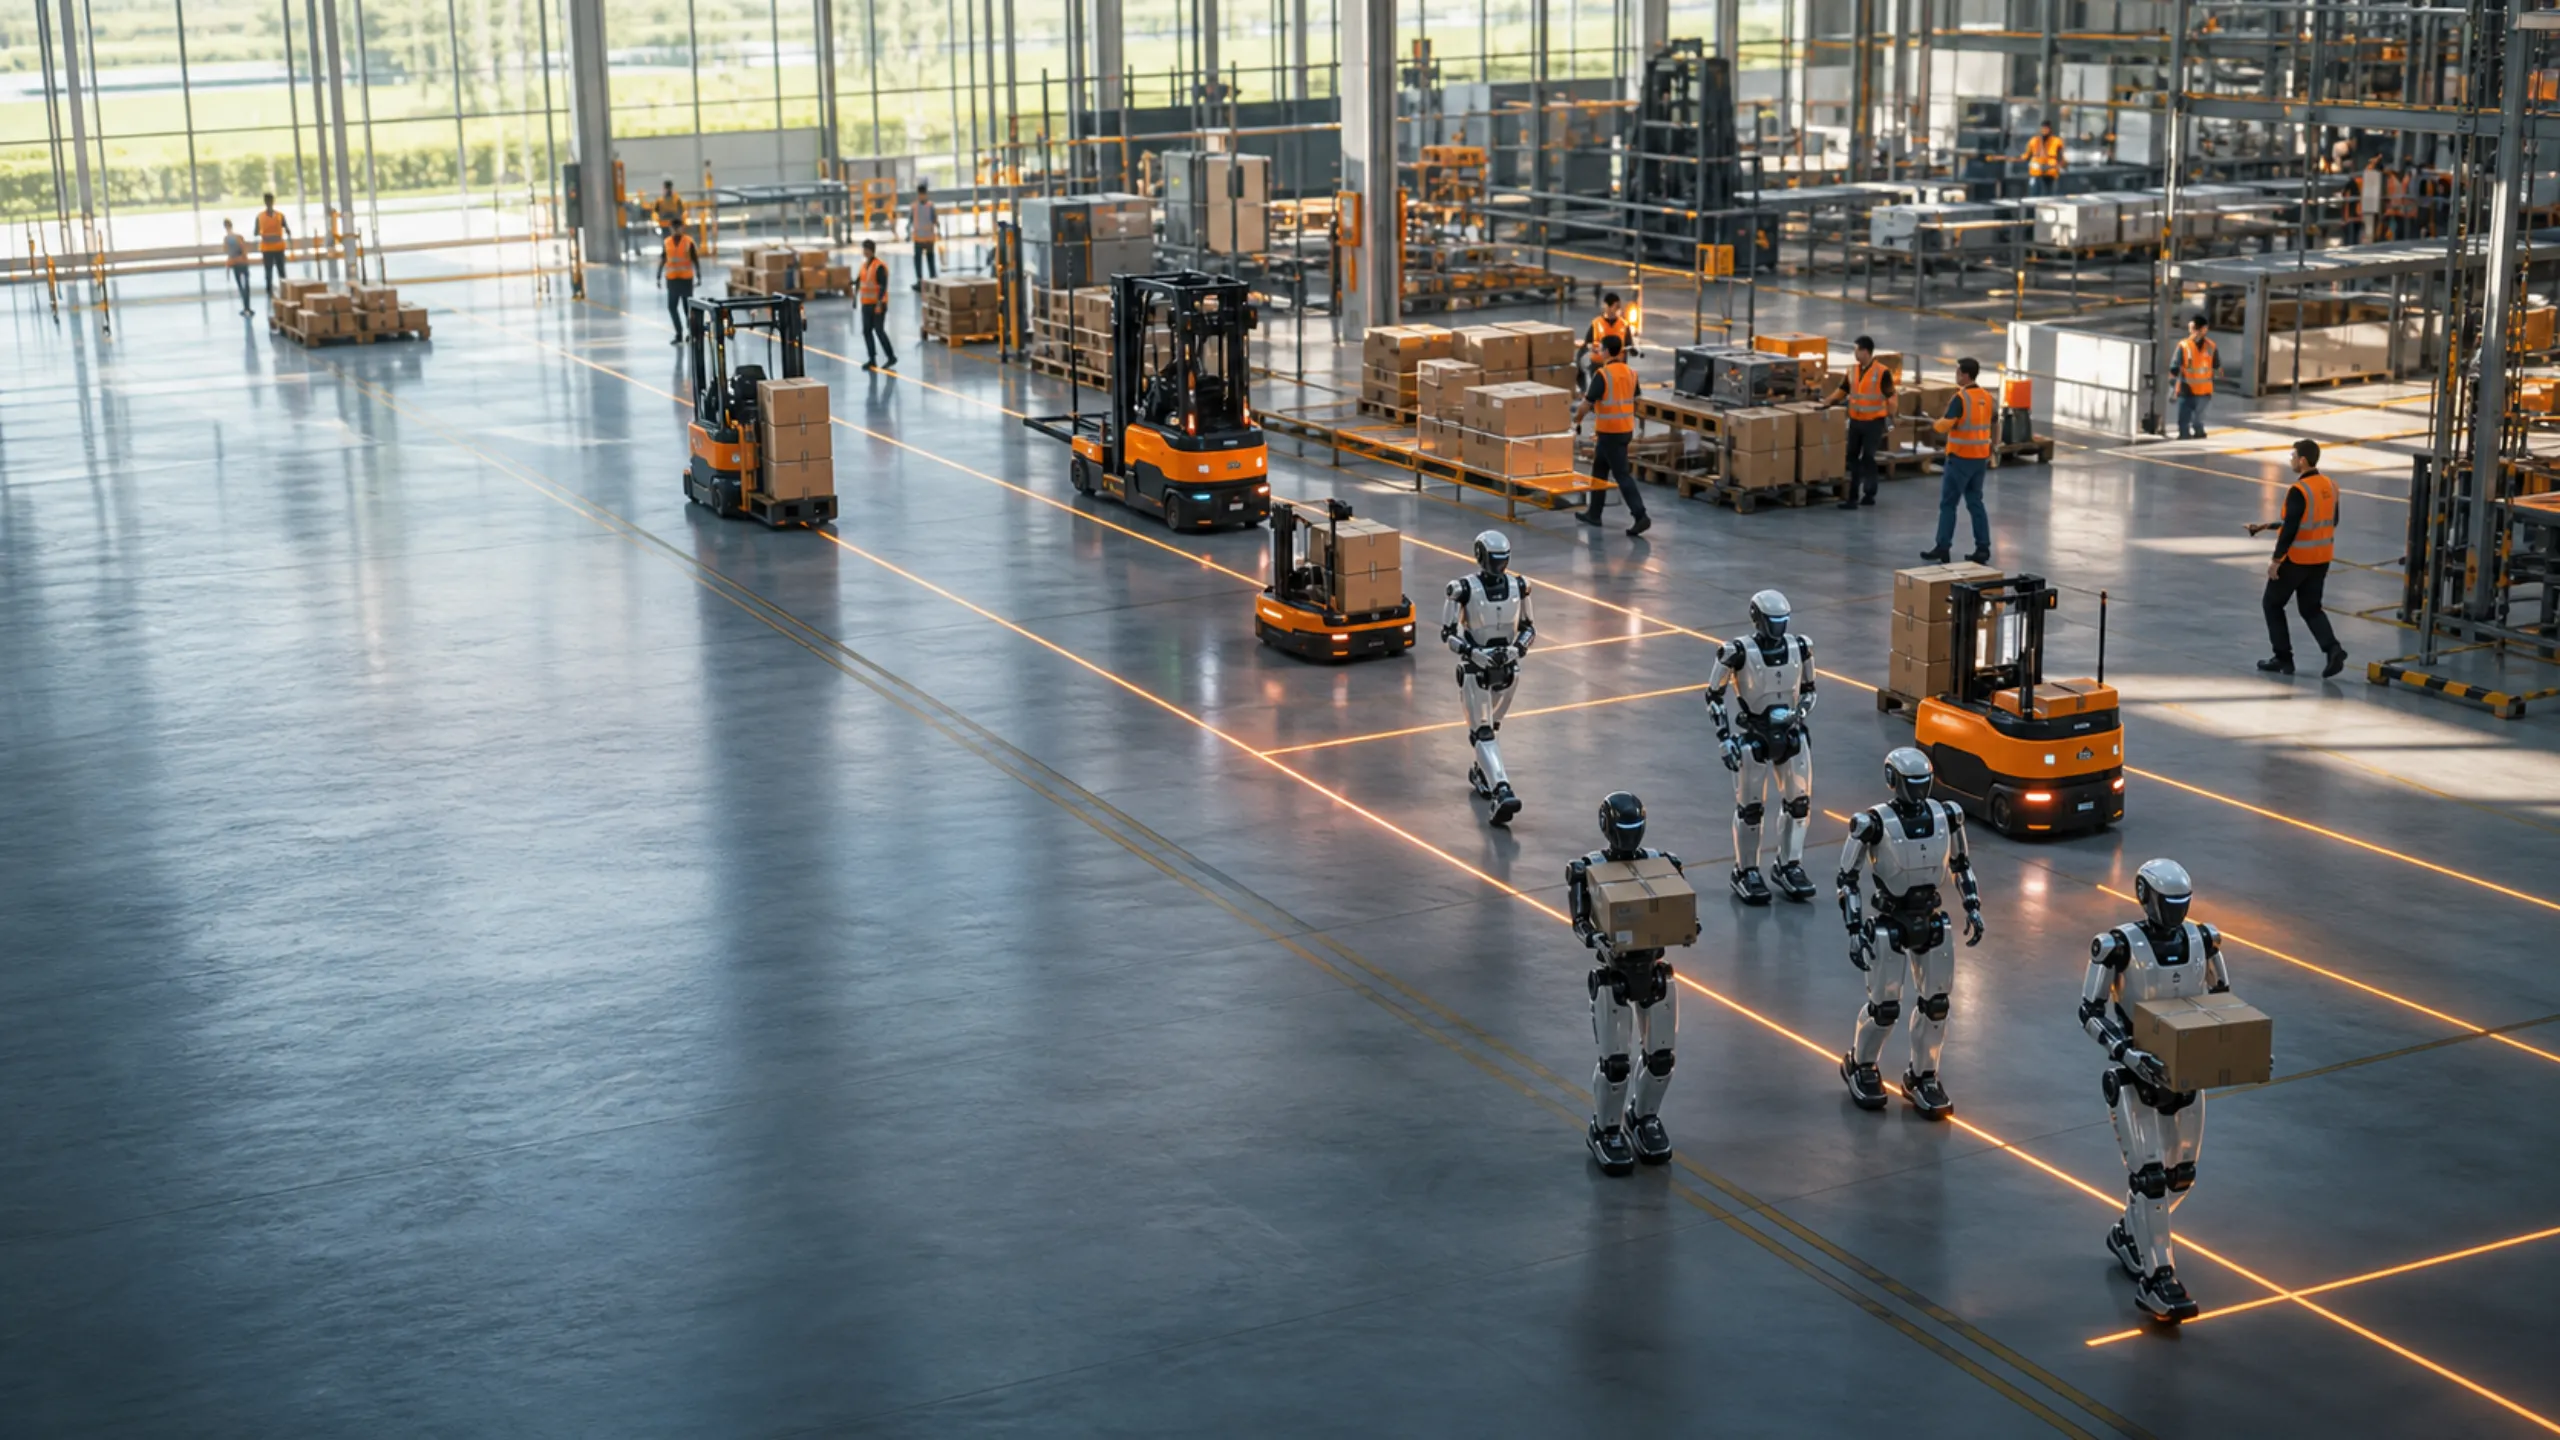
swarmREFLEX brings local responses to missionSTACK. Models help frame the mission; declared contracts bound the action. Developed through fleet simulation research.
Explore the approach ↓Enabling The Sovereign & Industrial Frontier
One mission. Three timescales.
Models reason about exceptions. Coordinators assign the work. Local rules handle immediate responses. Our research separates those jobs.
Know the world.
Connect assets, people and observations to the operation.
Coordinate the mission.
Coordinate assignments and routes. Make overrides reviewable.
Respond in time.
Keep local decisions inside declared limits. Test specialised models against simple rules.
What we have built and tested
Logic for hard limits. Models for incomplete context.
The swarmCORTEX simulator includes a swarmREFLEX simulation mode with hand-written, reciprocal velocity-avoidance logic. It is a simulated control rule, not a learned model. Exact fleet assignment provides another deterministic reference for testing narrow decisions.
Separately, a small joint assignment model was trained against the exact solver and evaluated on held-out simulation seeds. At a 10-second tag age, it agreed with the exact teacher on 64.8% of per-agent decisions, compared with 51.1% for an always-nearest heuristic on the degraded view.
Those numbers measure decision agreement in an offline simulation evaluation. They do not measure field safety, throughput or a model operating inside the live simulator. swarmREFLEX is the product direction for taking this work toward site-specific integration and validation.
The next step
Build the capability. Prove the boundary.
Explore the operation and inspect decision evidence within missionSTACK. Verify inputs, timing, limits and operator authority before a field trial.